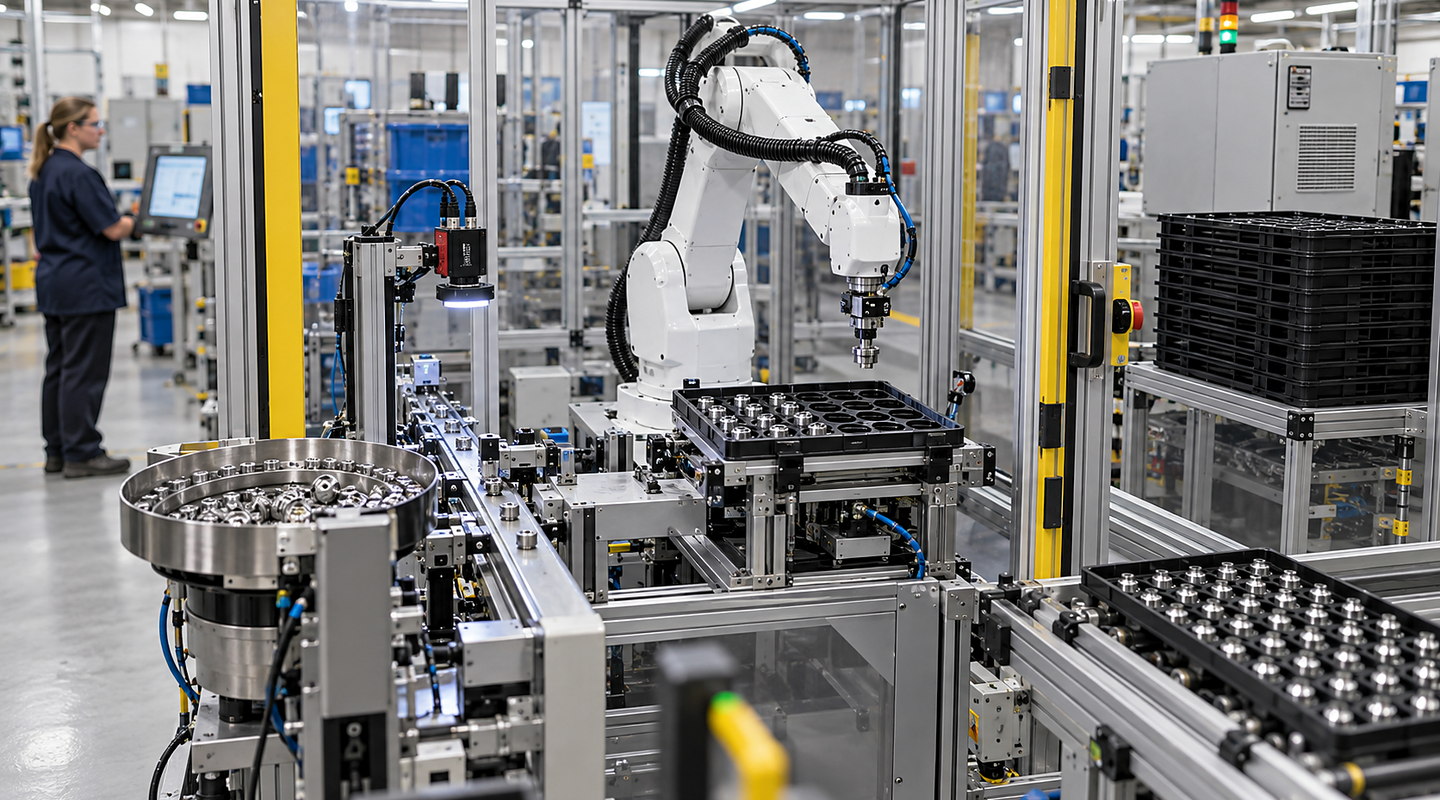
Robotic Pouch Handling: How the Process Works
Follow the operating sequence for robotic pouch handling, from preparing the input and controlling the main task to handling exceptions and checking results.
Plan robotic pouch handling from the filled pouch as presented through pickup, transfer, release and the required placement. Use representative packs across the intended weight, shape and surface range, including normal wrinkles and product distribution, and define acceptable grip areas.
Compare the complete sequence before choosing a handling arrangement. The pouch variation guide and run-off guide help define the evidence and assessed response to missing pouches, damaged seals or interrupted cycles.
Understand the complete route from input to accepted output — Robotic Pouch Handling
Follow the pouch from arrival to its required placement, including pickup, transfer and release. Agree what confirms an acceptable result and how an uncertain outcome is held for review. Completion of robot movement alone does not establish that the pouch was released and placed as required.
Discuss your application

Four clear stages for robotic pouch handling
At each stage, you can review how part, product and process variation for robotic pouch picking & transfer and run-off criteria and production evidence affect the next commitment.
- 01
Observe the Current Process and Collect Representative Samples
Supply filled pouches across the intended weight, shape and surface range. Record normal wrinkles, product distribution, arrival conditions and relevant drawing, recipe or artwork revisions, together with acceptable grip areas and the required placement.
- 02
Prove Handling and Process Risks in a Focused Feasibility Trial
Compare pickup, transfer and release using the representative packs and agreed grip areas. Record how variation affects the required placement and identify missing-pouch, damaged-seal or interrupted-cycle cases that need an assessed review or trial.
- 03
Design and Build the Complete Guarded Cell
Define proposed tooling and line interfaces, including pouch availability and downstream readiness. Agree the information needed between pickup, transfer, release and placement, with a response when the pack or result cannot be confirmed.
- 04
Run Agreed Scenarios and Support Production Ramp-Up
Record results against the agreed pouch range, placement and complete production pattern. Include assessed exceptions, recovery and changeover responsibilities, training and unresolved cases so handover reflects the conditions actually examined.
Decisions and results stay connected
| Stage | What happens | What you can review |
|---|---|---|
| Observe the Current Process and Collect Representative Samples | Confirm the requirements for robotic pouch picking and transfer, the operating range and the definition of a good result. | Your samples, current information and any points that still need confirming. |
| Prove Handling and Process Risks in a Focused Feasibility Trial | Compare workable methods using part, product and process variation for robotic pouch picking & transfer and arrival pattern and presentation from your real production. | The trial method, observations and reason for the recommended route. |
| Design and Build the Complete Guarded Cell | Resolve required cycle and production pattern, tooling, sensing and process interfaces and the physical, control, safety and data connections. | The agreed layout, line connections and any changes from the proposal. |
| Run Agreed Scenarios and Support Production Ramp-Up | Check normal, difficult and fault conditions before your team takes over the system. | Results for operator access, recovery and changeover and run-off criteria and production evidence, plus actions and operating information. |
Keep connected responsibilities clear
Your final robotic pouch handling scope must also account for operator access, recovery and changeover, run-off criteria and production evidence, current regulations and the conditions at your site.
- Cycle time depends on the complete process rather than robot speed alone.
- Part presentation, tolerances and recovery cases must be included in feasibility work.
- Collaborative operation or automatic handling cannot be assumed safe without an application assessment.