Requirement
State the required pickup, transfer, release and placement for the intended filled-pouch range. Identify acceptable grip areas, the production pattern, the result reviewer and the response when a pack or placement cannot be accepted.
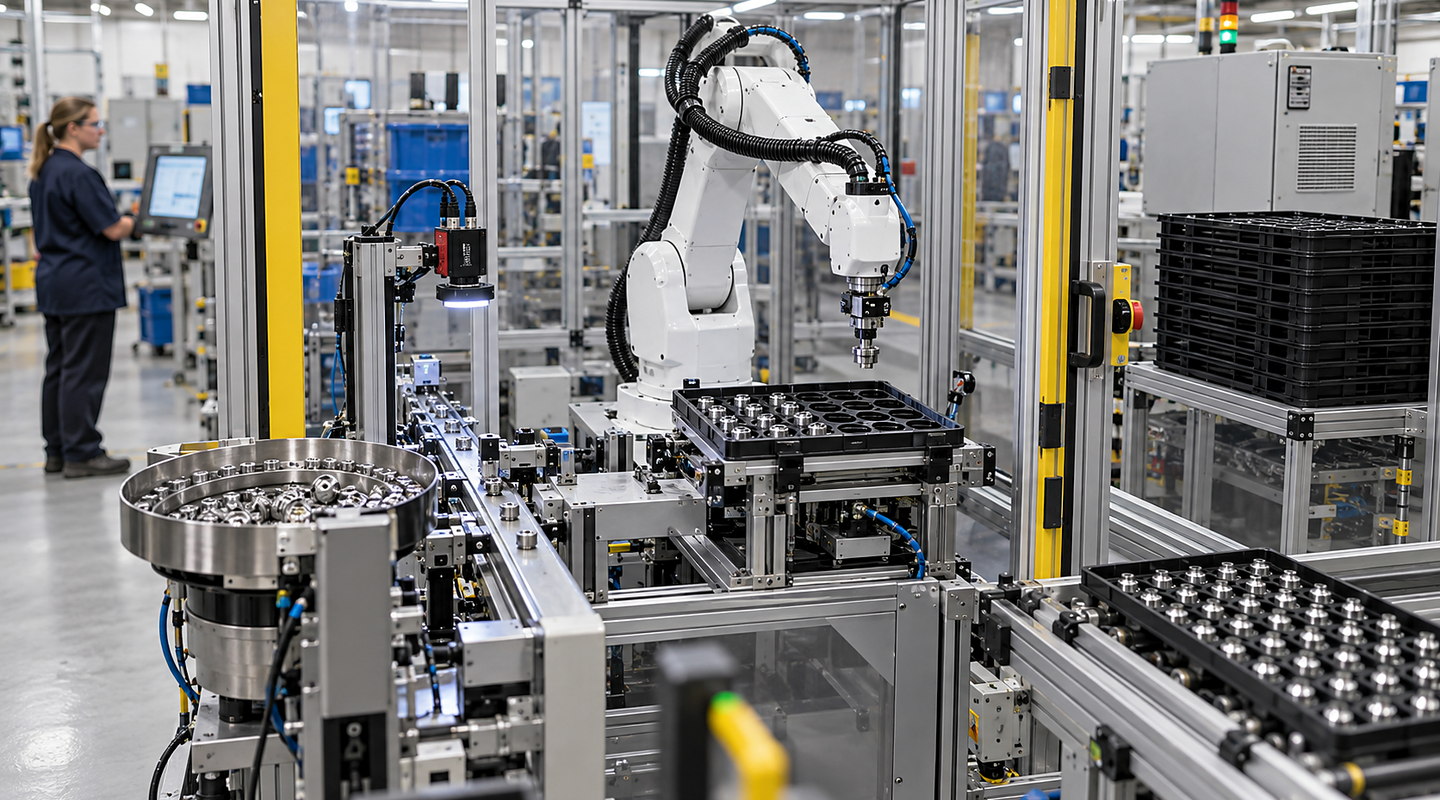
Use this practical checklist to describe your requirements for robotic pouch handling around representative parts, tooling and the complete process sequence, line connections and required results.
A useful pouch-handling brief defines the filled-pouch range, arrival conditions, acceptable grip areas and required placement. State the complete-cycle requirement and what evidence will confirm acceptable pickup, transfer and release.
Separate confirmed facts, realistic ranges and untested assumptions. Use the acceptance guide to agree representative packs, result records and the response to missing pouches, damaged seals or interrupted cycles.
Plan robotic pouch handling around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. A clear brief should state the operating range for part, product and process variation for robotic pouch picking & transfer and your requirements for run-off criteria and production evidence.
Discuss your application
State the required pickup, transfer, release and placement for the intended filled-pouch range. Identify acceptable grip areas, the production pattern, the result reviewer and the response when a pack or placement cannot be accepted.
Record pouch weight, shape, surface condition, normal wrinkles and product distribution, with arrival variation and relevant revisions. Separate intended production conditions from missing-pouch, damaged-seal and interrupted-cycle cases used in the assessed plan.
Agree representative filled pouches, the assessed method, repetitions and acceptable results for pickup, transfer, release and placement. Specify the records and review needed for uncertain outcomes and conditions not covered by the trial.
For robotic pouch handling, use “shall” only for a requirement that can be demonstrated. Keep preferences, assumptions, provisional line connections and future options clearly separate.
Your final robotic pouch handling scope must also account for operator access, recovery and changeover, run-off criteria and production evidence, current regulations and the conditions at your site.