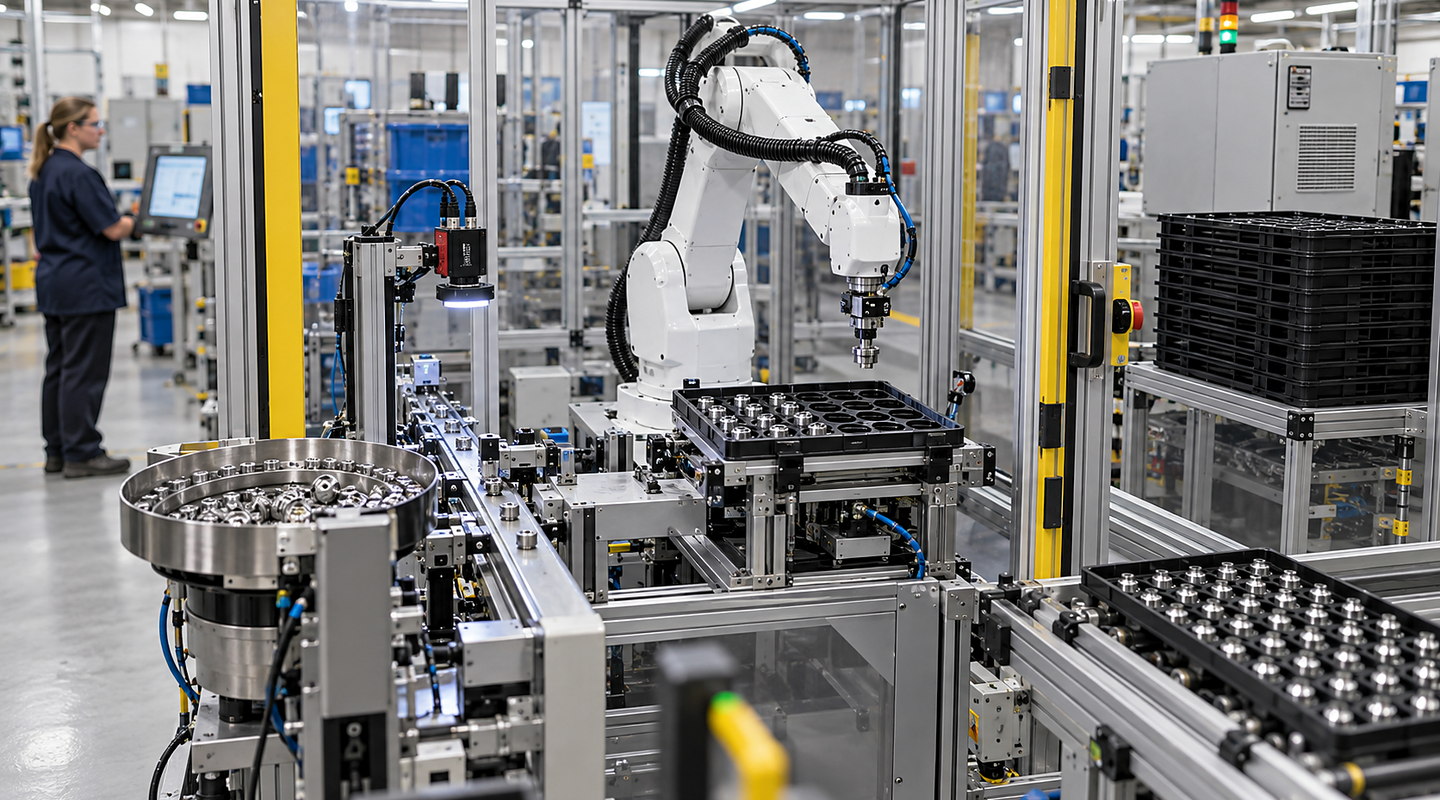
Robotic Pouch Handling Run-off and ramp-up checklist
What evidence should be agreed before acceptance testing for robotic pouch handling?
In brief
Agree representative filled pouches, the assessed method, repetitions and acceptable results before run-off. Judge pickup, transfer, release and required placement together, using the agreed grip areas and pouch-condition range.
Record how normal variation and credible exceptions were examined, including who reviews uncertain results. The specification checklist should identify the requirement that each result is intended to demonstrate.
On the production floor
Turn your production information into clearer decisions — Robotic Pouch Handling
Plan robotic pouch handling around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. Use this guide to resolve run-off criteria and production evidence before it limits the final system.
Run-Off Criteria and Production Evidence: condition, range and effect on your process
Current condition
Record the pouch revision, filled weight, shape, surface condition, wrinkles, product distribution and arrival condition represented by the trial. Keep the observed handling and placement result, reviewer and uncertainty with that record.
Realistic range
Cover the agreed normal and difficult pack range and production pattern. State which missing-pouch, damaged-seal and interrupted-cycle cases are included in the assessed plan and which conditions remain unexamined.
Effect on the system
Distinguish completion of the commanded movement from evidence of pickup, release and the required placement. Agree any pouch-condition checks needed and record accepted and uncertain outcomes separately; do not infer a checking capability from the robot motion.
Before you contact us
Five questions about run-off criteria and production evidence for your application
Who can confirm this information?Identify the person responsible for run-off criteria and production evidence in production, quality, engineering or operations.
How representative is the sample?Include age, supplier, batch, environment and upstream process state where they affect robotic pouch handling.
What is the difficult condition?Use an assessed method for credible missing-pouch, damaged-seal and interrupted-cycle cases. Record the required indication, hold, review and resumption conditions without assuming automatic detection, seal inspection or recovery.
How will you judge the result?Agree the method, repetitions, acceptable range, result record and the response if the observed result falls outside the agreed range.
What else must be coordinated?Your final robotic pouch handling scope must also account for operator access, recovery and changeover, run-off criteria and production evidence, current regulations and the conditions at your site.
Connected details
Review run-off criteria and production evidence as part of the complete system
Question 1
Part, Product and Process Variation for Robotic Pouch Picking & Transfer
For Robotic Pouch Handling Run-off and ramp-up checklist, describe the current position, required outcome, acceptable limits and known exceptions for part, product and process variation for robotic pouch picking & transfer. That lets us compare options against your real production rather than one nominal value.
Question 2
Arrival Pattern and Presentation
For Robotic Pouch Handling Run-off and ramp-up checklist, describe the current position, required outcome, acceptable limits and known exceptions for arrival pattern and presentation. That lets us compare options against your real production rather than one nominal value.
Question 3
Required Cycle and Production Pattern
For Robotic Pouch Handling Run-off and ramp-up checklist, describe the current position, required outcome, acceptable limits and known exceptions for required cycle and production pattern. That lets us compare options against your real production rather than one nominal value.
Question 4
Tooling, Sensing and Process Interfaces
For Robotic Pouch Handling Run-off and ramp-up checklist, describe the current position, required outcome, acceptable limits and known exceptions for tooling, sensing and process interfaces. That lets us compare options against your real production rather than one nominal value.
Question 5
Operator Access, Recovery and Changeover
For Robotic Pouch Handling Run-off and ramp-up checklist, describe the current position, required outcome, acceptable limits and known exceptions for operator access, recovery and changeover. That lets us compare options against your real production rather than one nominal value.
Question 6
Run-Off Criteria and Production Evidence
For Robotic Pouch Handling Run-off and ramp-up checklist, describe the current position, required outcome, acceptable limits and known exceptions for run-off criteria and production evidence. That lets us compare options against your real production rather than one nominal value.